

NTT’s Physics-Based World Model Screens Robot Actions Before Execution
Unite.AI
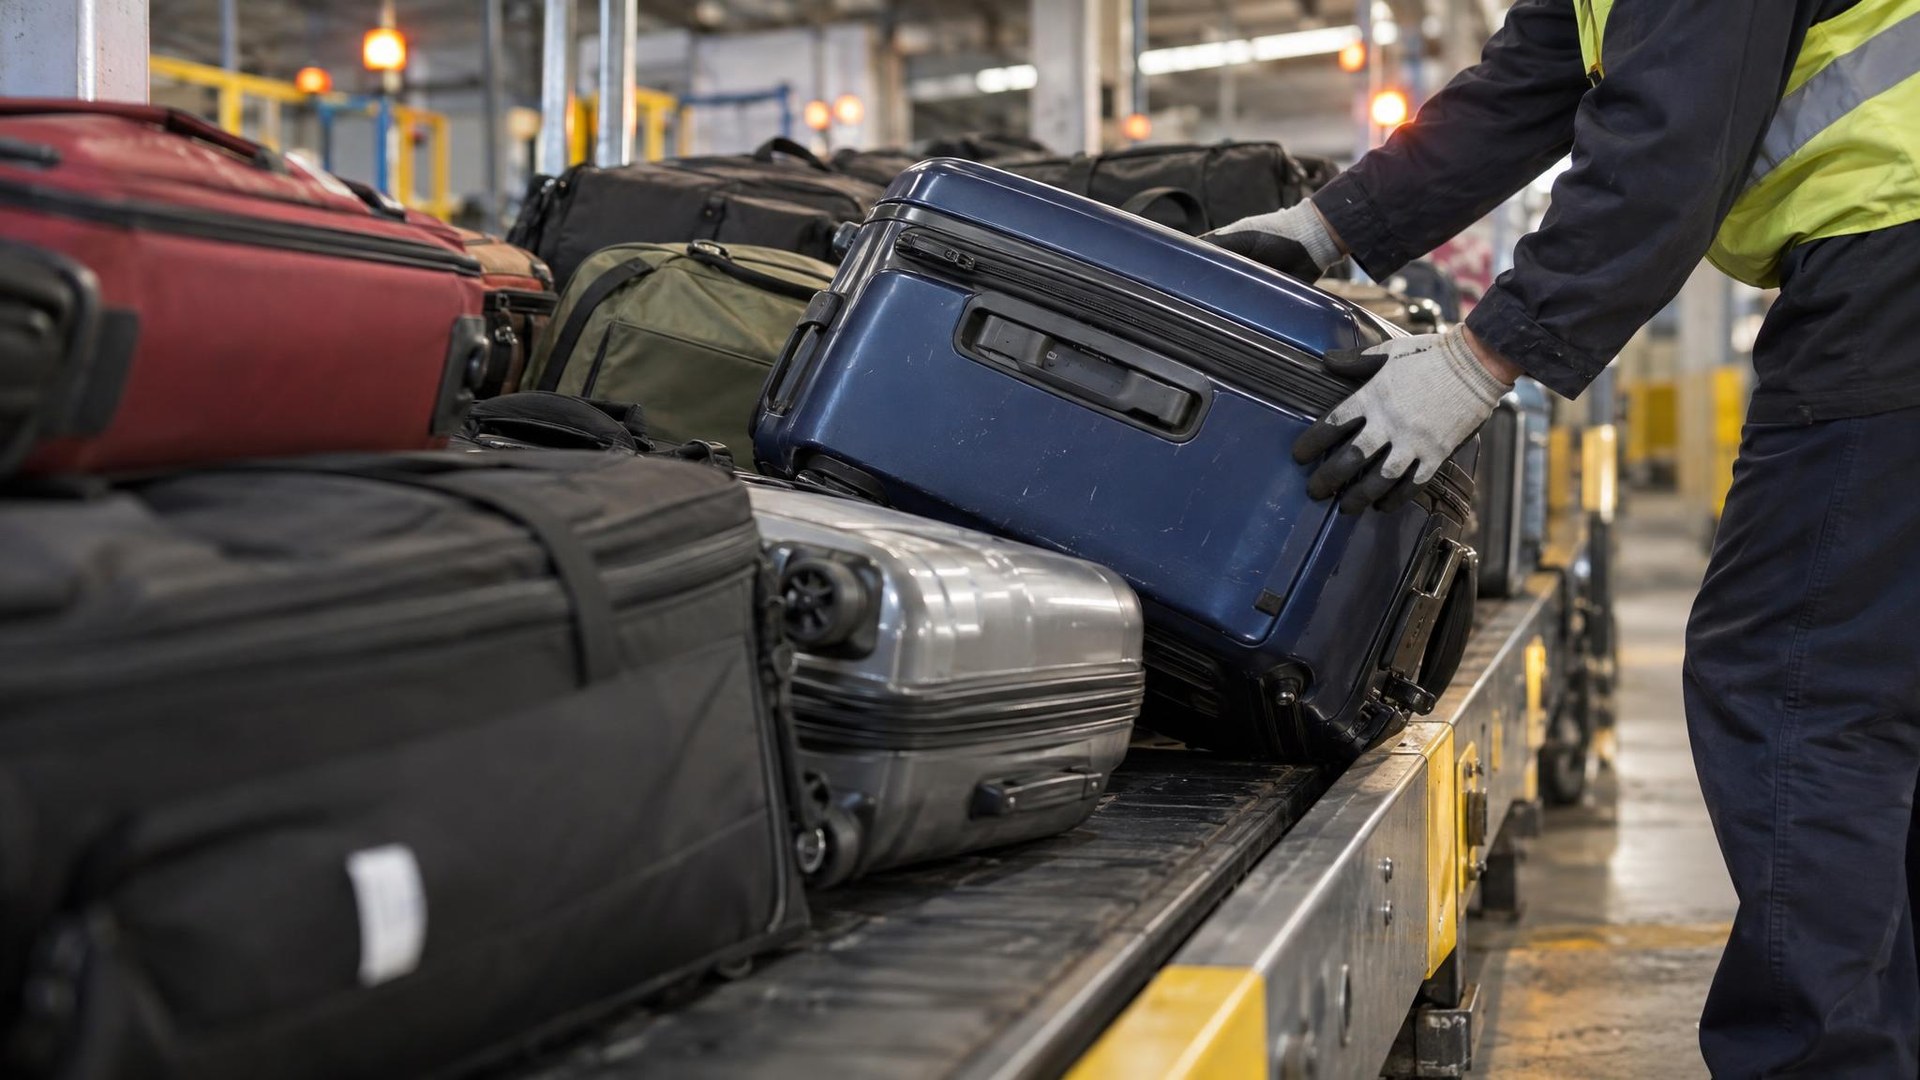
NTT developed a physics-based world model that predicts robot actions before execution, improving task success in shelf-loading robots from 73.1% to 92.3%. The model estimates physical properties to better predict collisions and load stability, aiding applications like airport baggage handling.